


ECE Research Seminar with Dr. Daniel Short: November 12, 12 – 1 p.m.
November 9, 2026
Image-Based Mapping, Localization and Navigation with Bio-Inspired Neural Networks Implemented on FPGA
Date: Thursday, November 12, 2026, 12:00 – 1:00 p.m.
Location: Simrall 104
Online
Abstract: Autonomous systems operating in complex and uncertain environments require robust methods for perception, mapping, and navigation that can function under tight size, weight, power, and latency constraints. This talk presents a bio-inspired neural network framework for imagebased mapping, localization, and navigation that is implemented on FPGA hardware. Drawing inspiration from biological vision and spatial cognition, this talk develops neural architectures that extract and encode visual features to support pose estimation, environment representation, and path planning using image landmark data. Then it describes FPGA-based implementations of these models, highlighting design tradeoffs in numeric precision, memory organization, and parallelism needed to achieve real-time performance. The talk will cover experimental results in both simulation and hardware-in-the-loop settings, including scenarios with limited communication and multi-robot cooperation. In the talk, Daniel will also share his lessons learned from integrating machine learning, digital hardware design, and test engineering, as well as practical insights from his doctoral path that may benefit current graduate students.
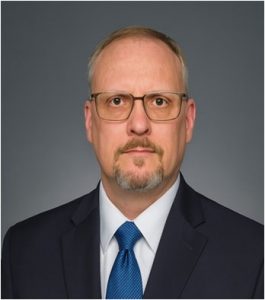 Daniel L. Short
 is a Northrop Grumman Technical Fellow and Staff Engineer in Electronics, specializing in FPGA-based architectures, digital hardware systems, and applied machine learning for mission systems. He received his Ph.D. in Electrical and Computer Engineering from Mississippi State University (under the supervision of Dr. Chaomin Luo), his M.S. in Electronics and Computer Technology from Indiana State University, and his B.S. with Honours in Electronic Engineering Technology from Excelsior College. Daniel’s research focuses on image-based mapping, localization, and navigation using bio-inspired neural networks implemented on FPGA, with applications to autonomous and multirobot systems in constrained communication environments. He has authored multiple peerreviewed articles on neural network–based navigation, biologically inspired neural networks in hardware, and multi-robot task allocation, and his work has been recognized with a Best Paper Award at the International Joint Conference on Neural Networks (IJCNN 2025) and presentations at the Cyber Awareness and Research Symposium (CARS’25). At Northrop Grumman, he applies these concepts to advanced digital hardware, test, and verification solutions for RF and radar platforms.
* For further information, contact: ECE 662-325-2035